
Julio Cesar Rodriguez Cervantes
PhD Student in Electrical Engineering · CINVESTAV Guadalajara
Multi-UAV systems · Bearing-only formation control · State estimation on S²
My research focuses on cooperative control of multi-UAV systems using only bearing measurements — no GPS, no distance sensors. Using robust nonlinear control techniques, I design formation controllers and state estimators that operate directly on the unit sphere S², enabling scalable drone swarms for GPS-denied environments.
News
- Released the open-source Gazebo simulations of four papers.
- Paper “Bearing Estimation on S² via Tangent-Space Measurements for UAV Formation Control” presented at CCE 2026.
- Invited talk at the Workshop on Robotics and Motion Planning, CIMAT.
Publications
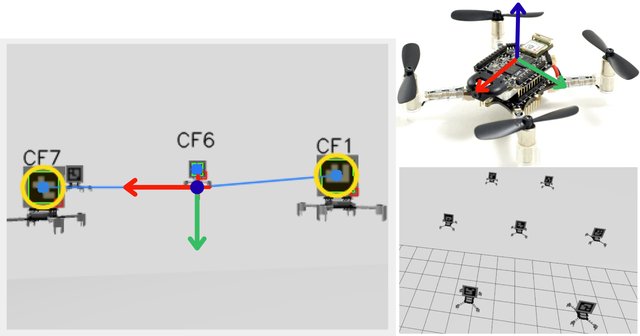
CCE 2026, pp. 1–6
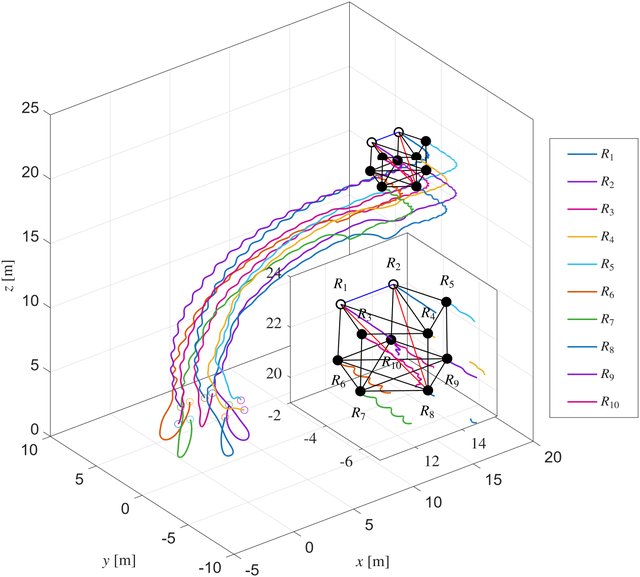
CCE 2025, pp. 1–6
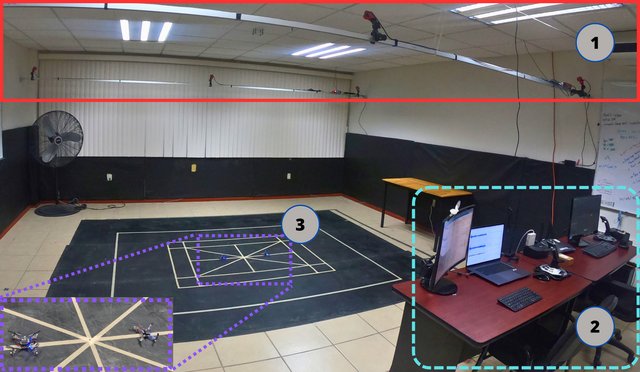
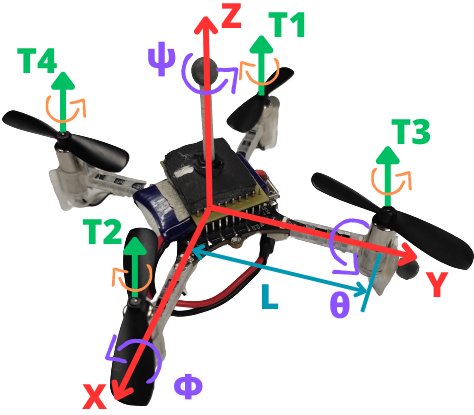
COMRob 2023, Xalapa, México
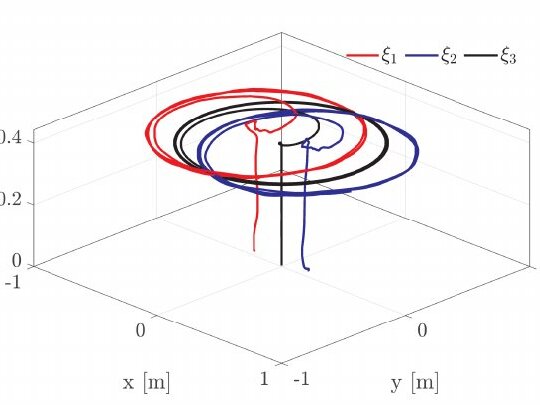
M.Sc. Thesis, Instituto Tecnológico de La Laguna, Torreón, Coahuila, México, August 2023
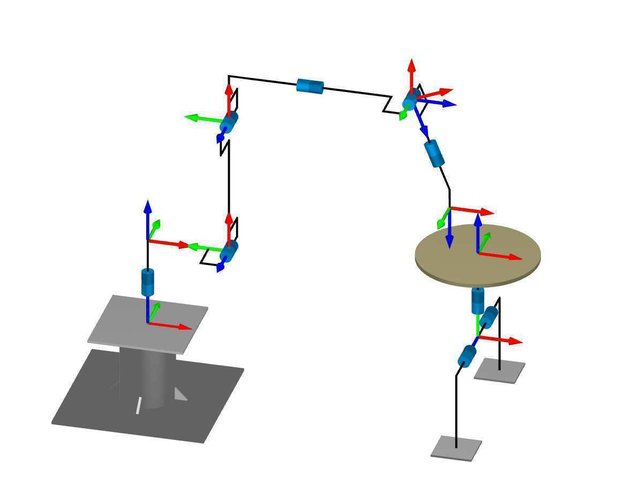
2021 XXIII Robotics Mexican Congress (ComRob), pp. 145–151
Simulations
101 drones forming letters
Sliding mode formation control in Gazebo. Drones drawn five times larger.
Projects
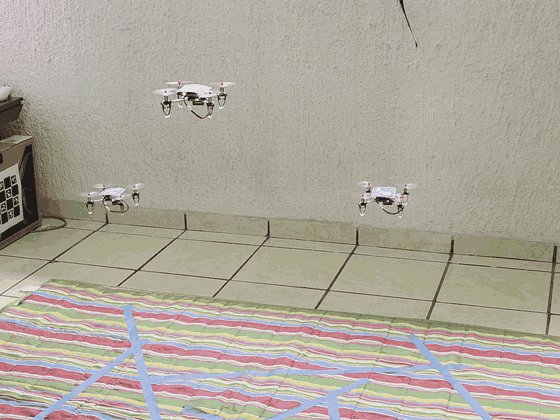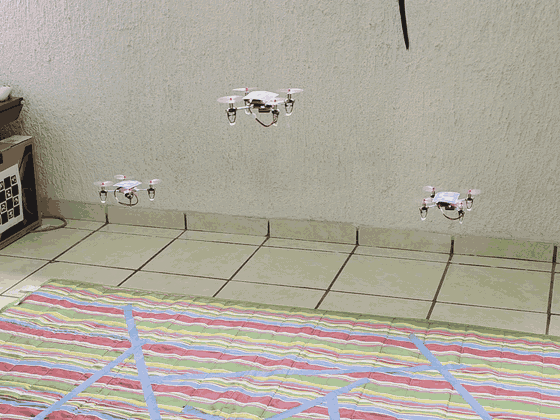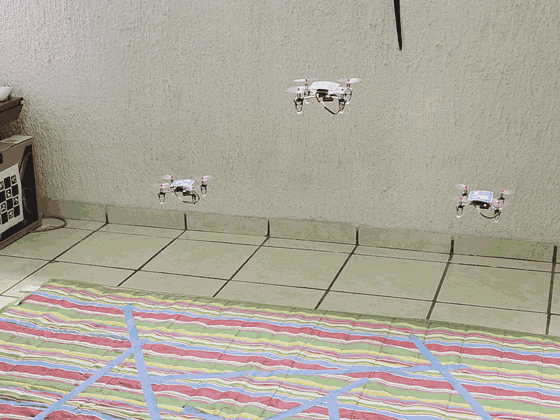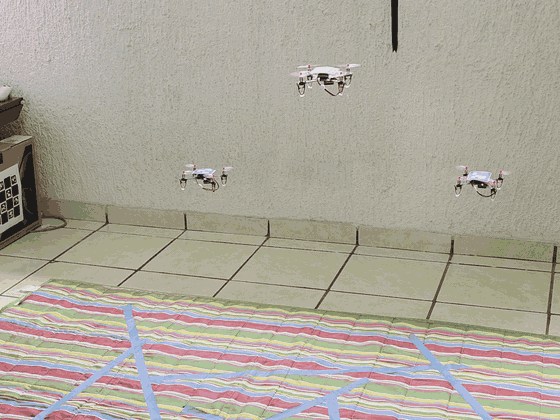
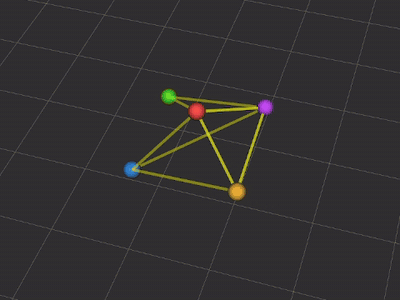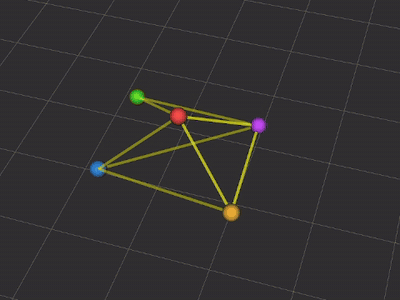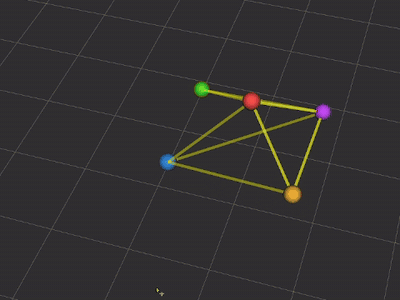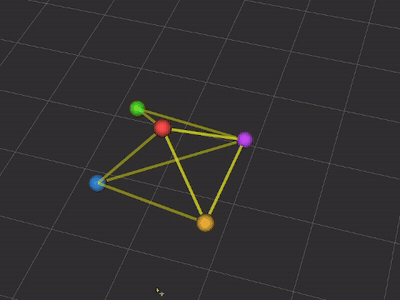
Real multi-quadrotor flights · Custom ESP-Drone platform · ROS 2 · 2026
Distributed sliding-mode controllers that make the team track a leader with time-varying velocity using only bearing measurements, compared in real flights. Runs on a custom ESP32-S3 flight-controller board with fully rewritten ESP-IDF 6 firmware and on-board bearing-only formation control. The clips show a real flight and the same experiment in RViz, with inter-agent bearings.
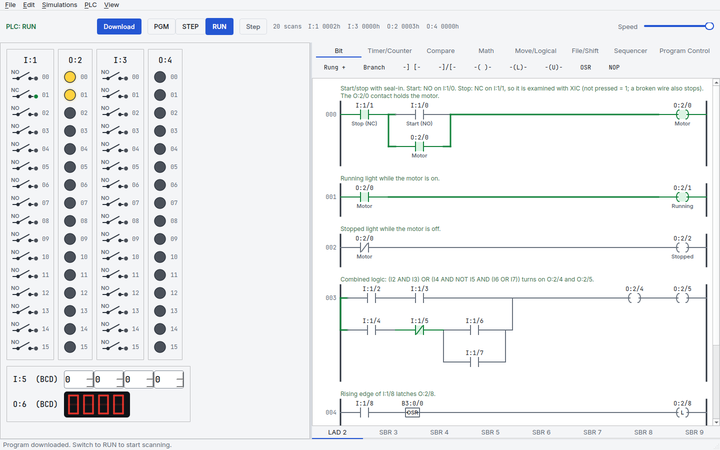
Python · PySide6 · GPL-3.0 · 2026
Write ladder, structured text or function block diagram programs, run them on a simulated PLC wired to fifteen animated machines (traffic lights, silo, tank PID loop, elevator, washing machine…), and check them against the requirements of sixteen exercises, without a teacher. Runs on Linux, macOS and Windows, and the ladder editor also runs right in the browser.
Experience
Professor in Higher Education. Design and teach the Automation and Control course for Mechatronics Engineering students.
Teach undergraduate courses at the Health Sciences Academy (Biomedical Engineering, Biotechnology Engineering, and Pharmaceutical Chemistry-Biotechnology programs). Courses include Analog and Digital Electronics, Electronic Circuit Design, Power Electronics, Kinetics and Dynamics, Advanced Programming, Calculus, Physiological Modeling, and Image Analysis and Processing. Designed course materials and labs for each.
- Installed and commissioned automation equipment and conveyor systems for PepsiCo Gatorade (Indianapolis, USA) and E80 Group (Chicago, USA) projects.
- Installed and configured LGV (Laser Guided Vehicle) robots and supervised electromechanical warehouse equipment.
- Managed inbound/outbound warehouse logistics and inventory using SAP, and trained technical staff on automated machinery.
- Collaborated with the CFE-Andritz-Hydroproject and CFE-Andritz-Seisa consortia on the repowering and modernization of the “Peñitas” and “Angostura” hydroelectric power plants.
- Oversaw contractual work schedules to ensure compliance with deadlines.
- Managed additional and extraordinary works, including reworks and incident handling.
- Oversaw inbound shipments at the warehouse and tracked material delivery at the construction site.
- Monitored personnel attendance records and man-hours worked per activity.
- Reconciled contractual schedules with stakeholders.
- Designed and taught Differential Equations and Integral Calculus courses for Mechatronics Engineering and Chemical Engineering students.
Education
Bearing-only formation control and estimation for multi-quadrotor systems, validated in simulation, HIL and real flights. Funded by SECIHTI.
Thesis: formation controllers for quad-rotor multi-agent systems with experimental validation on nano aerial robots (PDF, English version, stability analysis supplement). Funded by CONACYT (now SECIHTI).
Internship: control subsystem for a 2-DOF cooperating positioner for a Fanuc ARC Mate 100iC arc-welding robot.
Invited Talks
Certifications
- End-to-end application of Meta's Segment Anything Model 3 to computer vision segmentation workflows.
Languages
- Spanish — Native
- English — Professional working proficiency
Stack
Python C++ MATLAB ROS 2 LaTeX Linux ESP-IDF Gazebo Git EasyEDA